Rev C · Sep 2026 to now
V5 Wireless Tuning Bridge
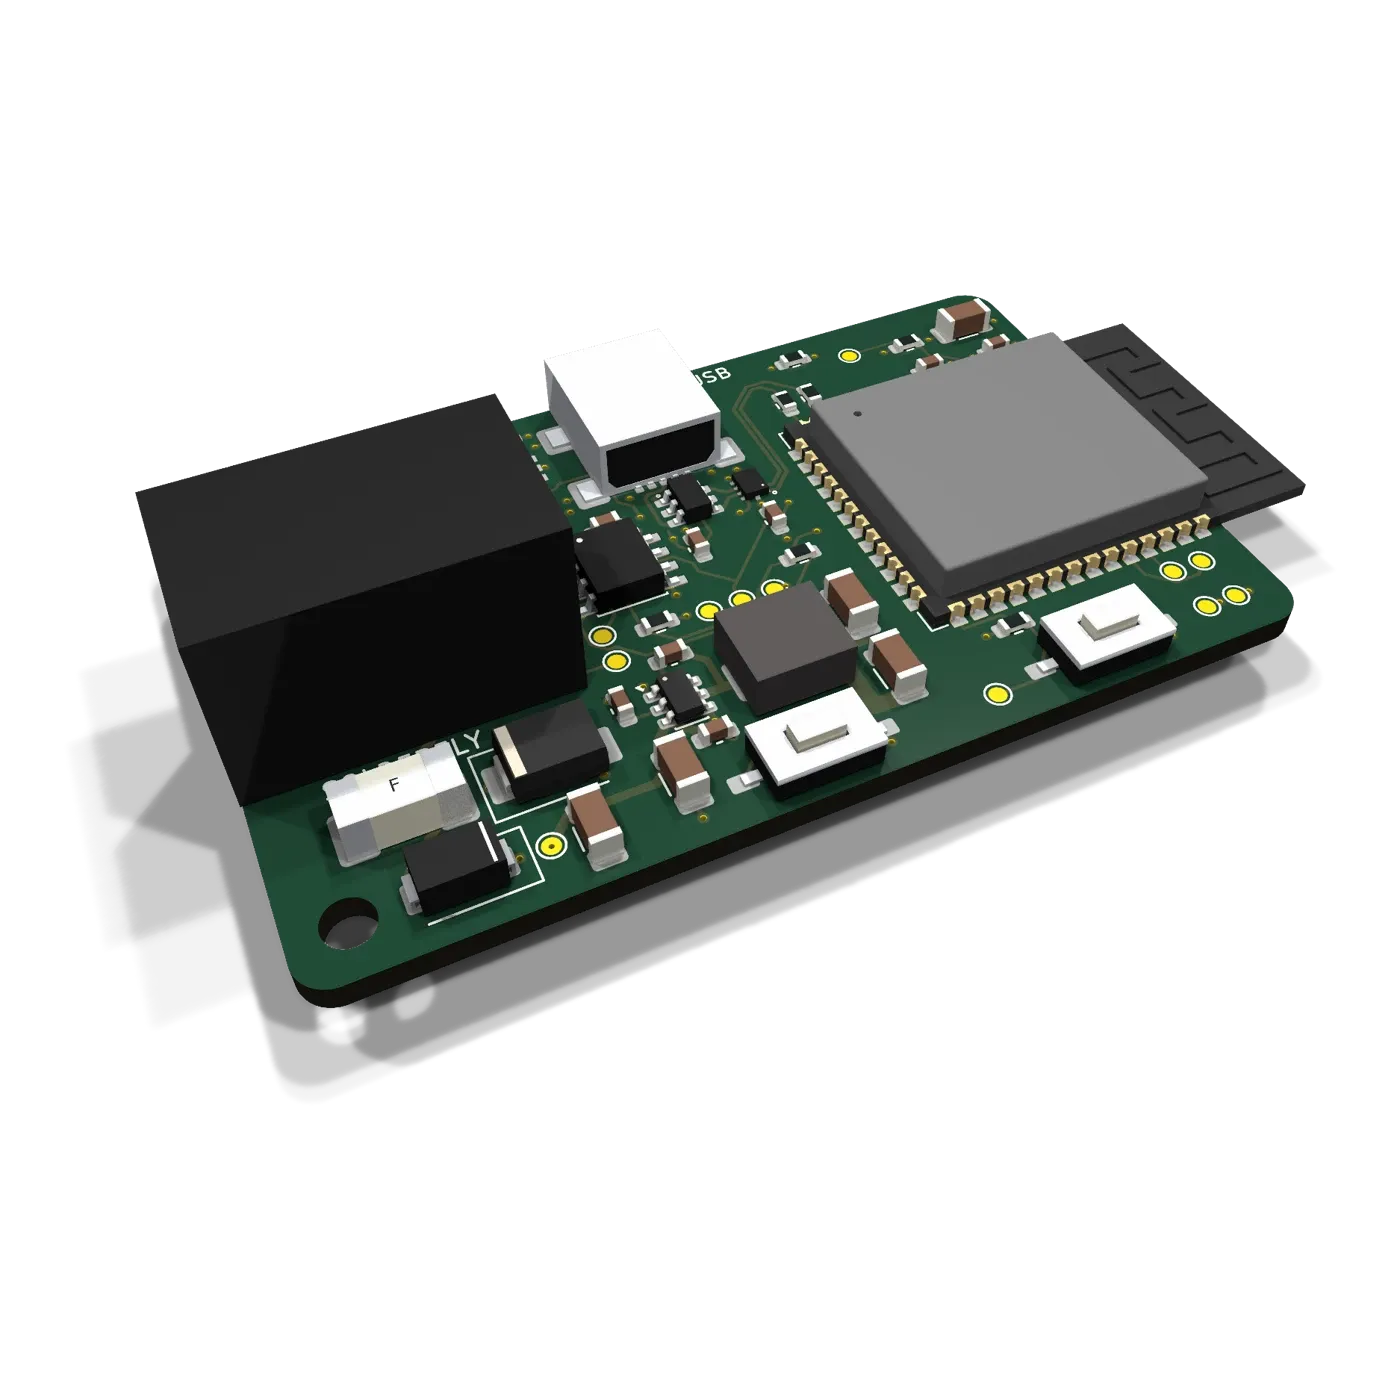
It's a small board that plugs into a spare Smart Port so a VEX robot can be tuned from a laptop over Wi-Fi, while it runs.
How I built itFrom the schematic to the source code.
I'm Isaac, a student in Sydney. I design robots and circuit boards, then write the code that brings them to life.
Each area has its own page with the projects behind it.
Every robot I've built since Year 6, and what each season taught me.
The projects I'd show someone first.
Rev C · Sep 2026 to now
It's a small board that plugs into a spare Smart Port so a VEX robot can be tuned from a laptop over Wi-Fi, while it runs.
How I built itAug 2026 to now
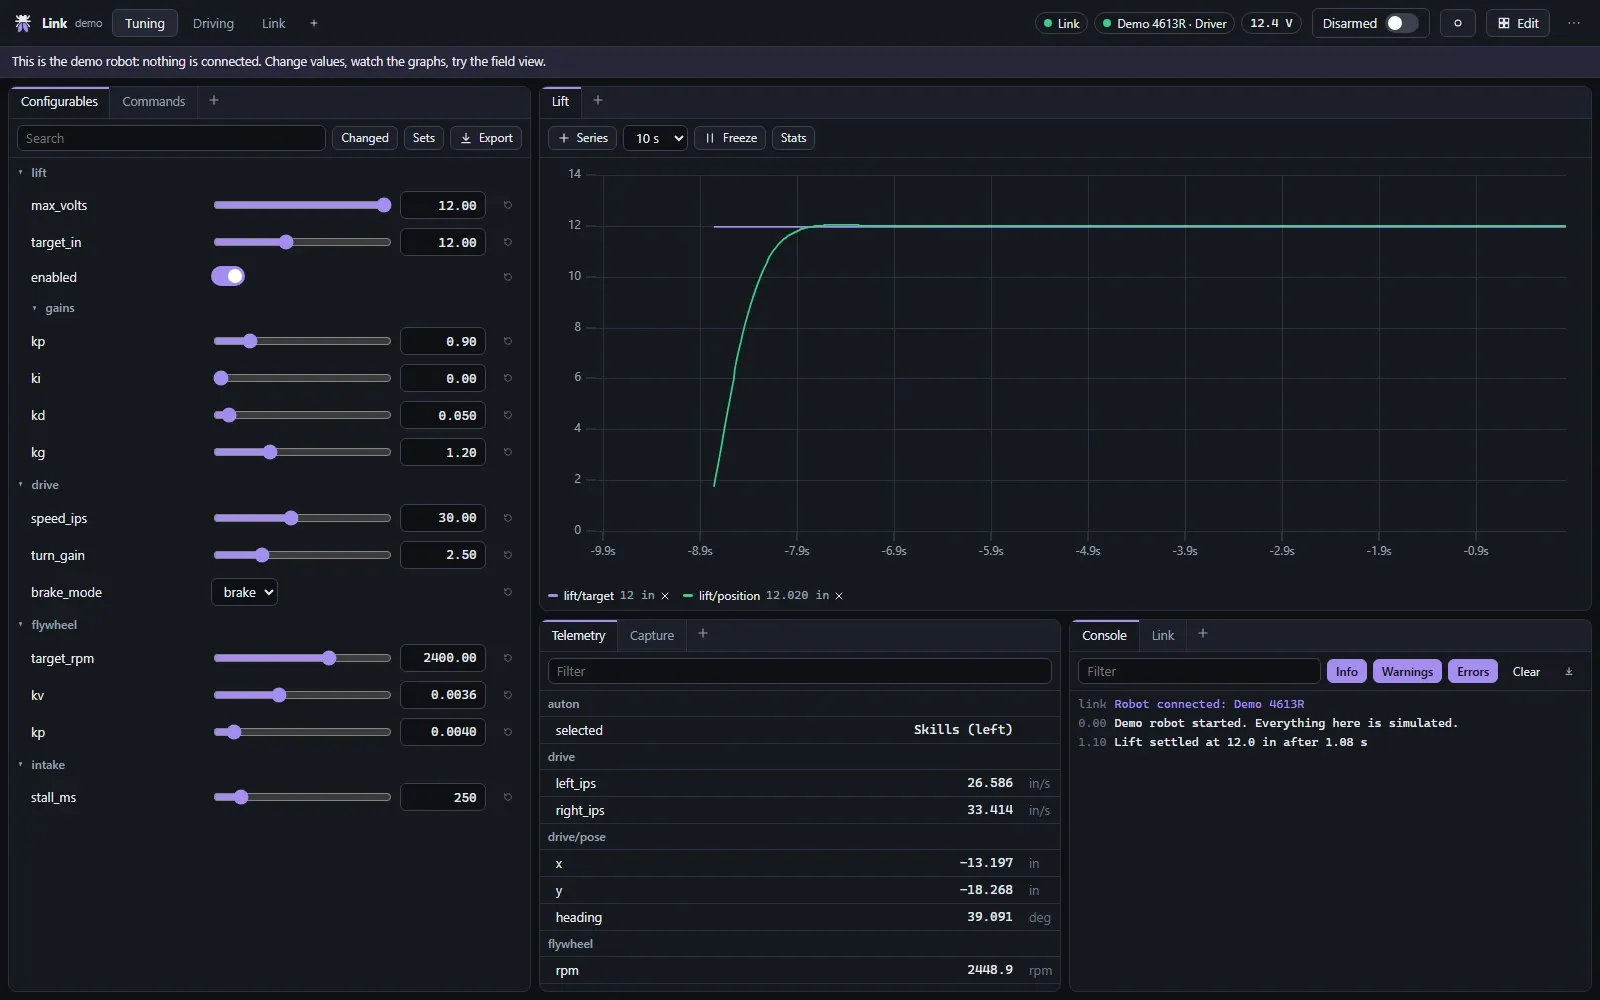
It's software for tuning a VEX robot while it runs, so you can change a gain and watch the robot respond straight away. It started as a dashboard cabled to the Brain and grew into a wireless system.
How I built itv0.2 · Aug 2026 to now
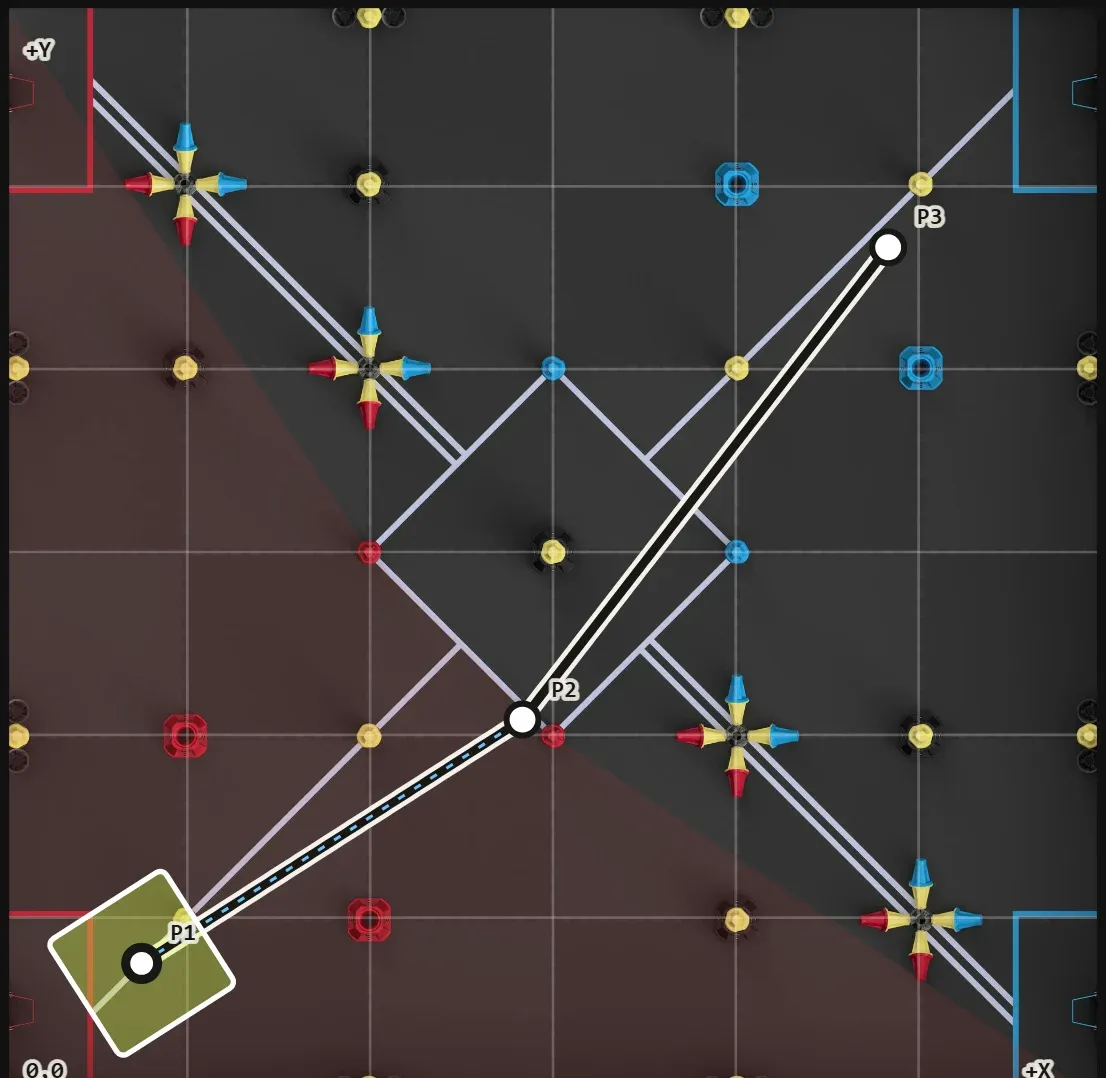
It's a motion-planning library and browser path editor that works out where the robot should be at every moment of a route. It now drives 4613R's competition autonomous.
How I built itContact
I'm always up for talking robotics, code and student projects. Email is the best way to reach me.
isaac.hronopoulos@gmail.com