Aug 2026 to now
Live Tuning
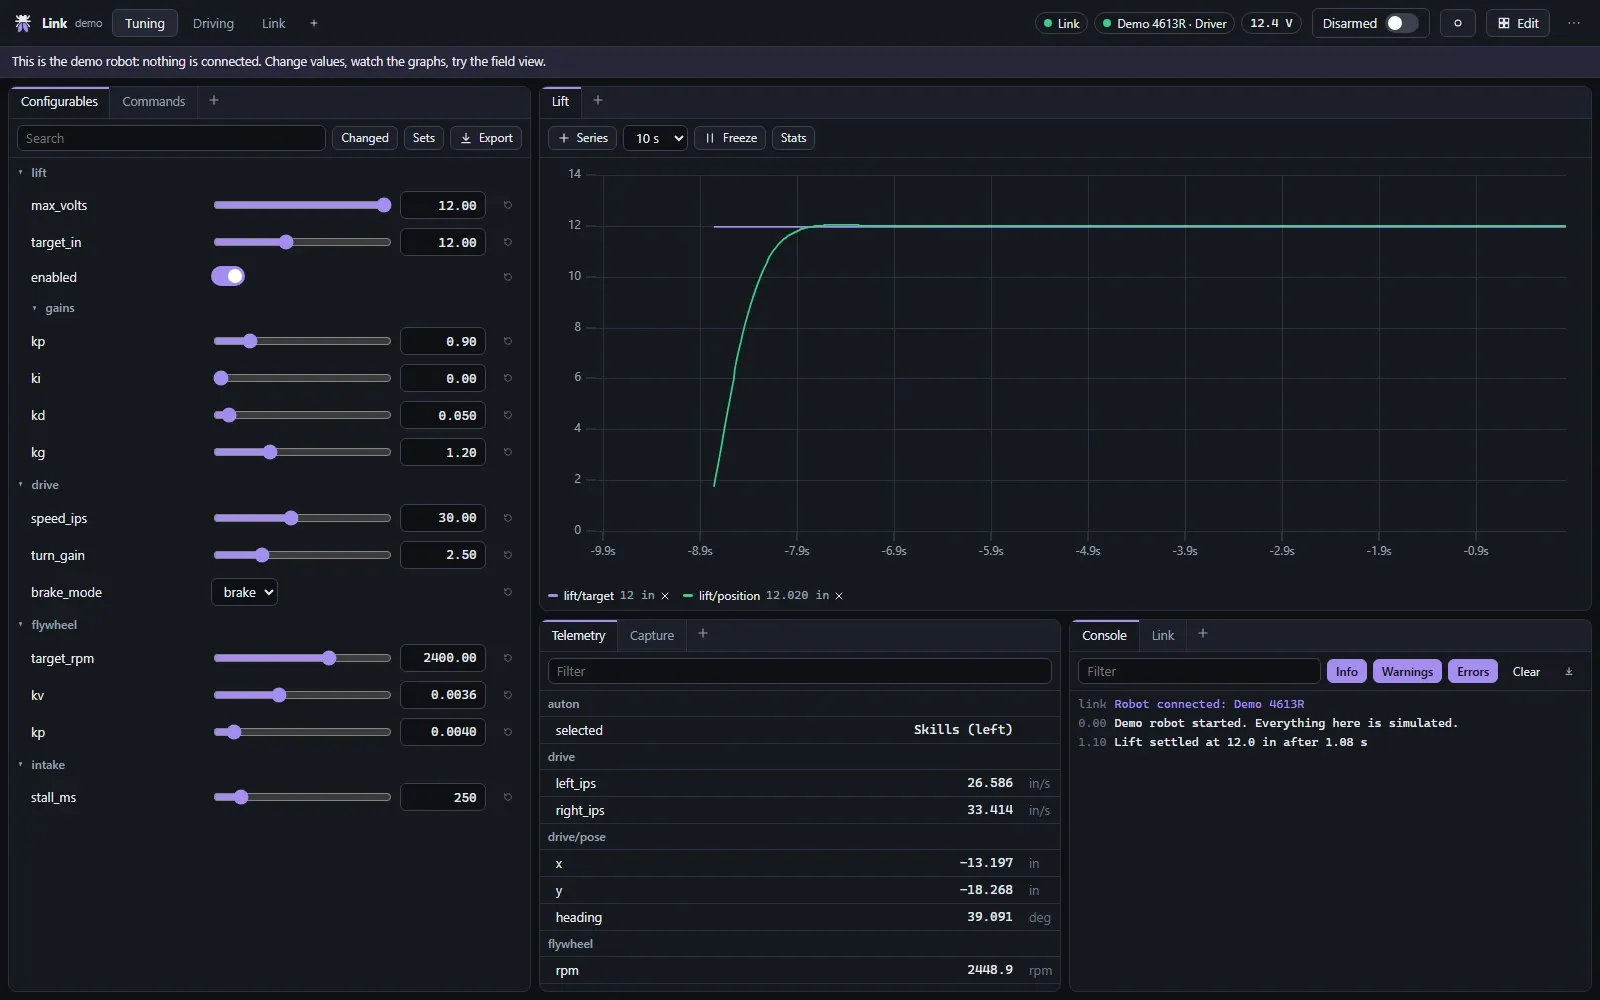
It's software for tuning a VEX robot while it runs, so you can change a gain and watch the robot respond straight away. It started as a dashboard cabled to the Brain and grew into a wireless system.
How I built itWork / Programming
Libraries, control code and tools I have written.
Aug 2026 to now
It's software for tuning a VEX robot while it runs, so you can change a gain and watch the robot respond straight away. It started as a dashboard cabled to the Brain and grew into a wireless system.
How I built itv0.2 · Aug 2026 to now
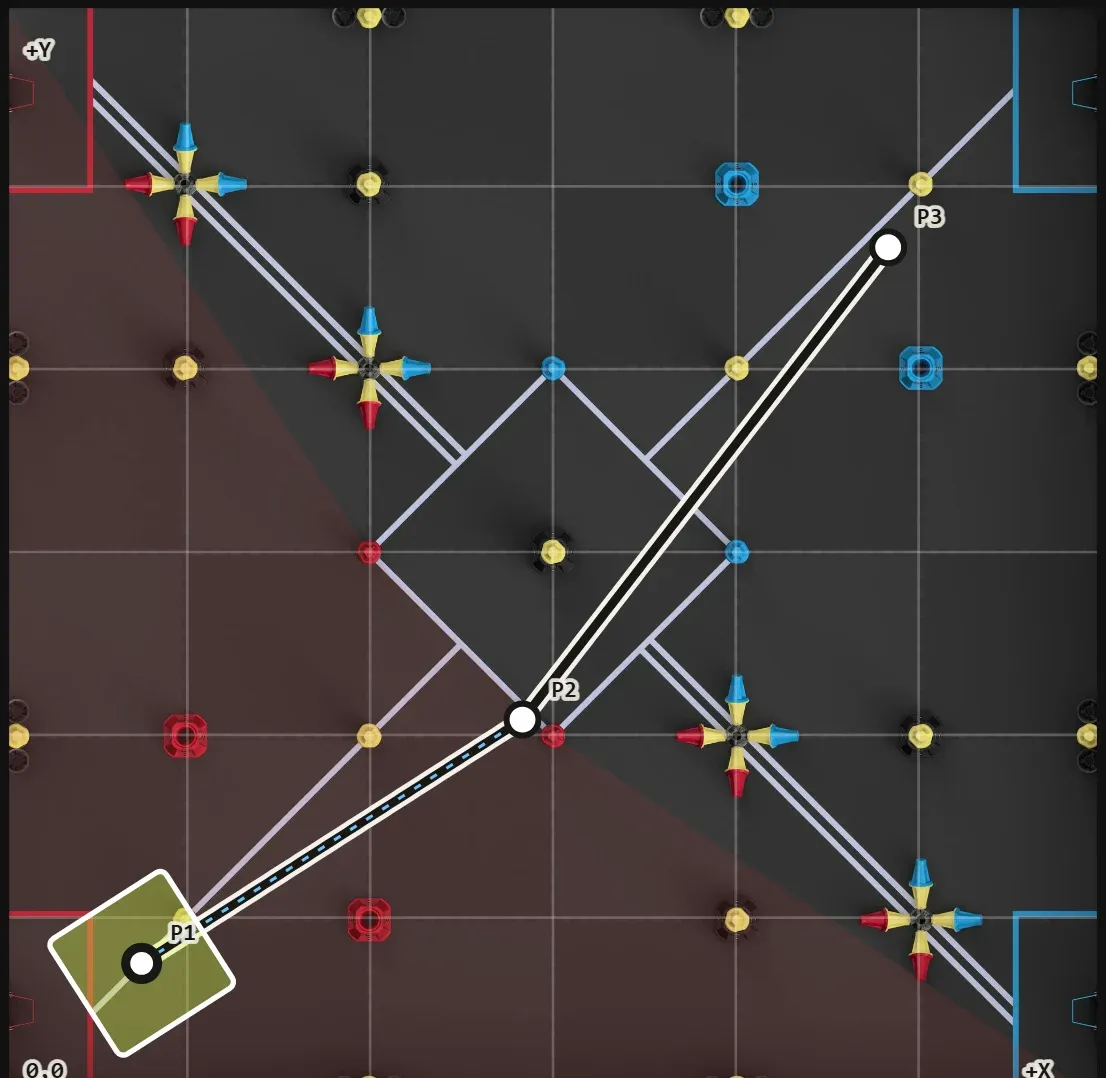
It's a motion-planning library and browser path editor that works out where the robot should be at every moment of a route. It now drives 4613R's competition autonomous.
How I built it